Spatial Ground Truth for Energy Operations

A plant model with a stated tolerance, built from the scans you already own. Every device resolves against it, so a technician sees which asset they are facing and at what elevation.

Augmented Reality for Oil and Gas Operations

One reference frame for the whole site
From tank farm to unit interior.
Position and orientation, so the overlay lands on the asset and not near it.
Built from capture you already own, in the formats you already hold.
Public cloud through to air-gapped, on the same API.
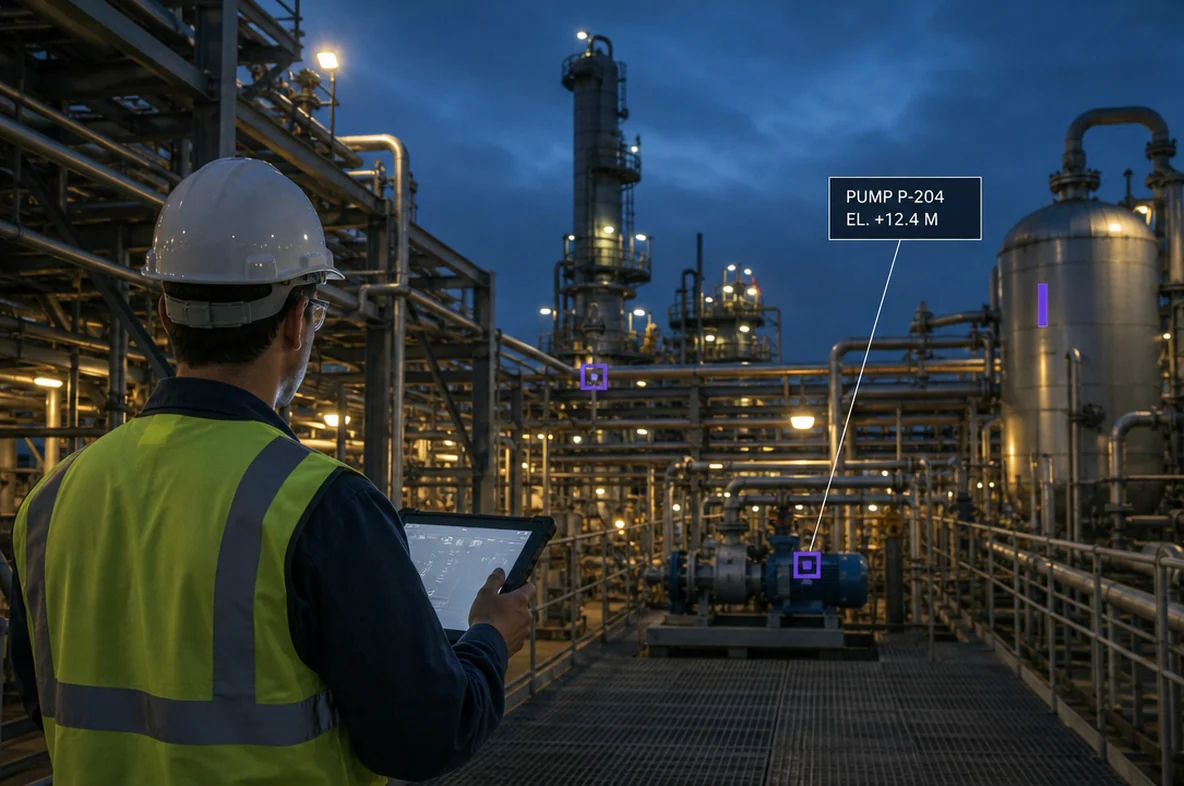
A technician with a tablet on a walkway in a refinery process unit at dusk, with markers on a pump, a valve and a vessel, and a label reading PUMP P-204, EL. +12.4 M
Why the twin stops at the fence line

The twin knows every valve on the unit. It has no idea which one the technician is facing, so the record stops where the fieldwork starts.

The Gap Between the Digital Twin and the Field

Nobody made a mistake. The information exists and it stops at the door.
A satellite fix greyed out beneath a steel pipe rack while a camera-based position stays locked. A single walkdown repeated by several different functions, each logging the same trip separately. A work order, a parts record and a 3D model each pointing at a different valve in a row of identical valves, none able to say which one is meant.

Satellite positioning fails where the work is

Steel superstructures, pipe racks and vessel interiors block GNSS. The dangerous case is not total denial but partial denial, where a receiver keeps reporting a position that is confidently wrong and nothing downstream knows to distrust it.

The cost is real and nobody owns it

Repeat walkdowns, travel to remote sites, duplicated surveys, revised lifting plans, decisions taken conservatively under physical uncertainty. It is paid across engineering, maintenance, operations, projects, inspection and HSE, so no single budget sees the bill and no single business case gets written.

Every system models the asset. None locates it.

The CMMS holds the work order, the ERP holds the part, the twin holds the geometry. Each is correct and each assumes somebody already knows which asset is in front of them. That assumption is the gap.

Asset Finding and Work Instructions, Upstream to Downstream

One map, and the information arrives where the work happens.
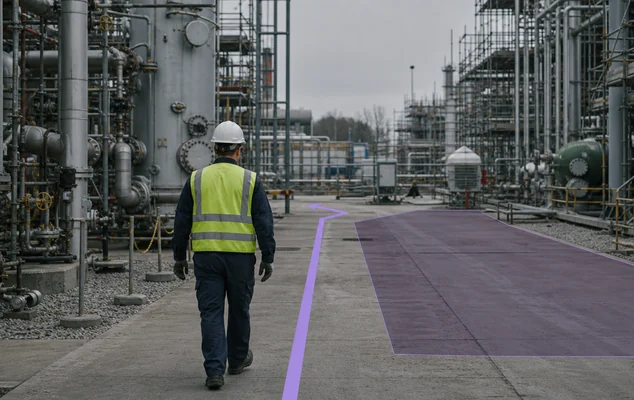
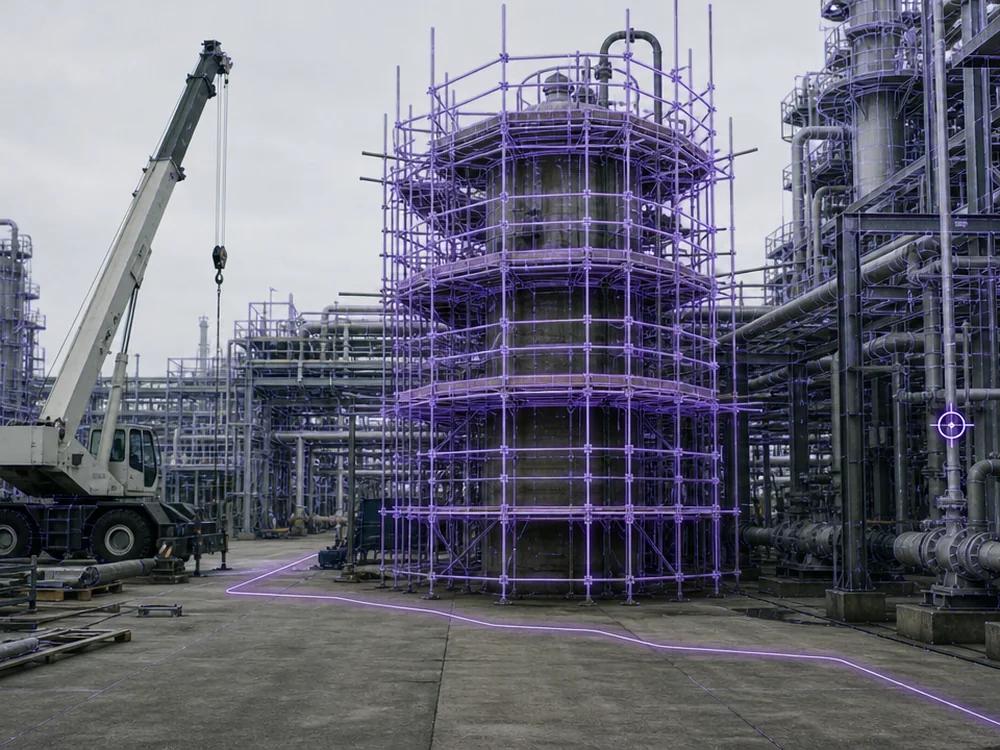
A contractor walking a routed path through a refinery during a turnaround, with a shaded zone marking an area the route avoids
Turnaround and contractor guidance
A shutdown fills the site with people who have never been in it. Contractors localize on entry and route by walking time, with permit-only areas excluded.
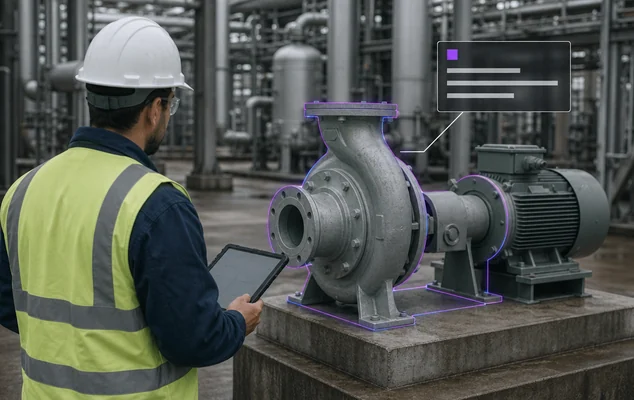
A technician with a tablet at a process pump, the pump outlined and an information panel anchored to it by a leader line
Point-of-work information
Work orders, procedures and equipment history anchored to the asset itself, read from the systems that already hold them. The record stays where it is. We hold the coordinate and the tag that points to it.
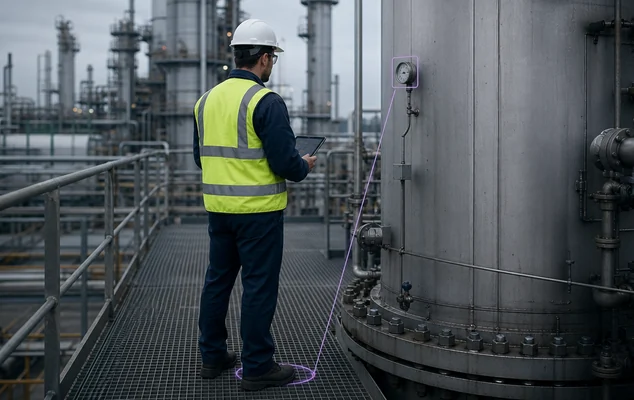
An inspector reading a gauge on a process vessel, with a marker on the walkway recording the position the reading was taken from
Inspection rounds and evidence of work
Route the inspector, confirm which asset a reading belongs to, and record the position it was taken from so the next visit reproduces the same view.

Object Tracking for Inspection and Isolation

Object Tracking recognizes a specific pump, valve or skid from its CAD or scan model and localizes against the asset rather than the room. For isolation checks, inspection and close-quarters work.

Ingest

Build the map from capture you already own. E57 and LiDAR point clouds, Matterport, Leica, NavVis, Faro, XGRIDS, 3D Gaussian Splats, 360 video, CAD or BIM. Use the right instrument per zone, aerial for the tank farm and handheld for the unit interior, and stitch them into one frame.

Localize

A single camera frame returns position and orientation in the plant frame. Georeference the map and the same pose comes back as latitude, longitude and heading, so a GIS or twin stack that already speaks those keeps speaking them.

Stay true

Scheduled re-checks hold the registration true through scaffolding, shutdowns and moved equipment. Map versioning keeps a partial re-scan in the same frame, and every position stays traceable to the version it was captured against.
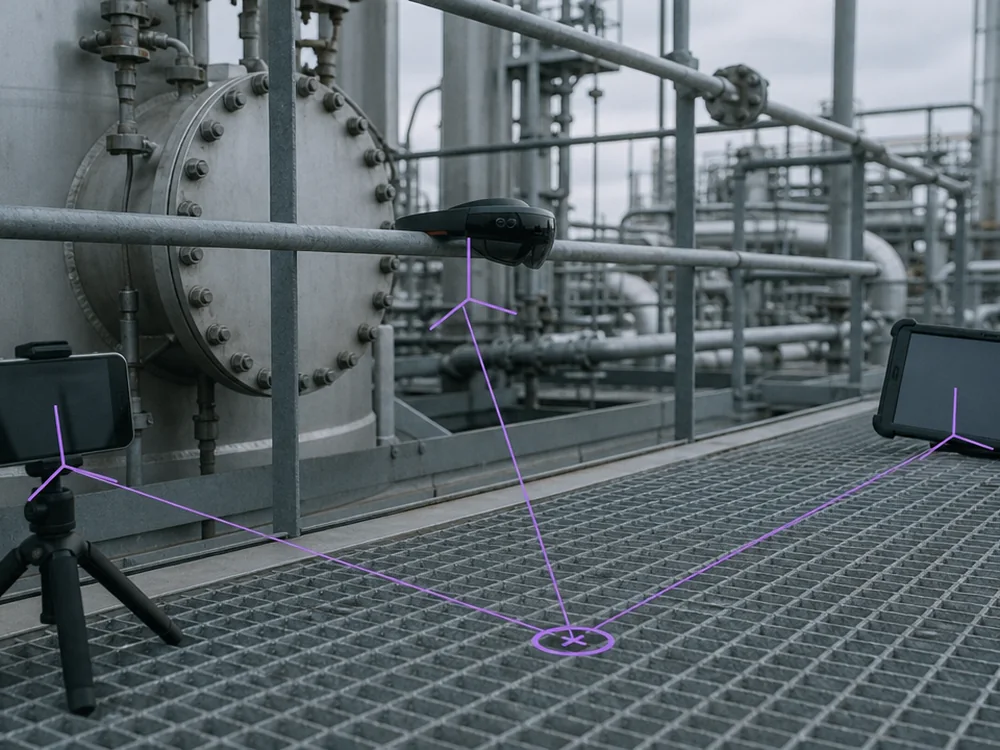
Drone capture of a tank farm and handheld scanning inside a process unit merging into one map. A phone, a headset and a tablet each returning a position and orientation from the same plant map. A process unit re-scanned during a turnaround, with anchors and routes holding their positions.

Scan-Agnostic Localization, Built as Infrastructure

Scan-agnostic
Build the map from E57, LiDAR, Matterport, 3DGS, 360 video, CAD or BIM. No proprietary scanner, no re-capture.
Cold-start localization
Absolute 6-DoF pose from a single camera frame on wake. No exploration run.
Two primitives, one SDK
VPS for the environment, Object Tracking for the equipment. Same map, same SDK.
Built for changing plants
Relocalization holds through scaffolding, shutdowns and moved equipment. A changed area is re-scanned into the same frame, and anchors and routes carry over.
Your map, your infrastructure
Public cloud, private cloud, self-hosted or fully on-device. In self-hosted and on-device modes, no maps, images or spatial queries leave your infrastructure.
Bounded drift
Periodic absolute relocalization holds onboard drift inside a stated tolerance.
Every platform
ROS 2, REST APIs, Unity, iOS, Android, WebXR and headsets ship from the same map.

On-Prem and Air-Gapped Positioning for OT Environments

A plant layout is competitive information. On regulated sites it can't leave the building.

MultiSet runs from public cloud to a fully air-gapped floor. We store a coordinate and a tag, and the asset master never moves.

Poses come back in your plant grid or WGS 84, on devices your teams already carry, intrinsically-safe ones included.
Diagram showing private cloud, on-prem and on-device deployment connecting to one MultiSet core that serves warehouse, factory, construction, healthcare and tunnel environments

Single-Capture and Multi-Capture Site Coverage Compared

Single-capture approachMulti-capture approach
How a site is coveredOne scan, one map, one instrumentMany scans joined into one coordinate frame
Past one scan's rangeCoverage stopsAdd a map and it aligns against the set
Instrument choiceWhatever the pipeline acceptsAerial for open areas, handheld for interiors, survey data where it exists
When an area changesRe-capture the whole mapRe-scan the changed area into the same frame
Where the frame comes fromThe vendor's pipelineYour plant grid, georeferenced to WGS 84

Stated plainly: a refinery is never one scan. The question is whether dozens of scans compose into one frame or stay separate maps.

Related explainers: GPS-denied navigation and E57 to VPS.

Use cases: field inspection and verification and frontline operations in the field of view.

On a site still being built: visual positioning for construction.

Oil and Gas VPS:
Frequently Asked Questions
How do technicians locate equipment in a refinery without GPS?

A visual positioning system matches what the camera sees against a pre-built 3D map of the plant. MultiSet returns absolute position and orientation from a single camera frame, inside steel structures, under pipe racks and on platforms where satellite signal is blocked or degraded. No beacons and no markers on equipment.

Does it work in a plant that changes, with scaffolding and shutdowns?

Yes. Localization holds through the visual change scaffolding and moved equipment create, and a changed area can be re-scanned and merged into the same coordinate frame without re-authoring anchors or routes. Every stored position is traceable to the map version it was captured against.

Can it use our plant grid and our equipment tags?

Yes. Maps accept plant grid or local survey coordinates with an EPSG code and georeference to WGS 84, so poses come back as latitude, longitude and heading. Your functional location and equipment tags stay the join key. We hold a coordinate and a pointer, never a copy of your asset master.

What scan data can I use to build the map?

Any of it. E57, LiDAR point clouds, Matterport exports, 3D Gaussian Splats, 360 video, CCTV footage and CAD or BIM all convert into localization maps. The capture you already own becomes the map, and you keep it.

Can MultiSet run on-premises or on-device?

Yes. Public cloud, private cloud, self-hosted and on-device. In self-hosted and on-device modes, no maps, images or spatial queries leave your infrastructure.

What devices can workers use in a classified area?

MultiSet is software and runs on the camera your team is already permitted to carry, including intrinsically-safe-certified wearables and tablets rated for hazardous areas. We do not certify hardware and make no intrinsic safety claim of our own.

One Frame for Every Contractor on Site